MessyNav: Zero-Shot Interactive Navigation via Manipulation in Messy Environments
Conference on Robot Learning (CoRL), 2026
* Equal contribution
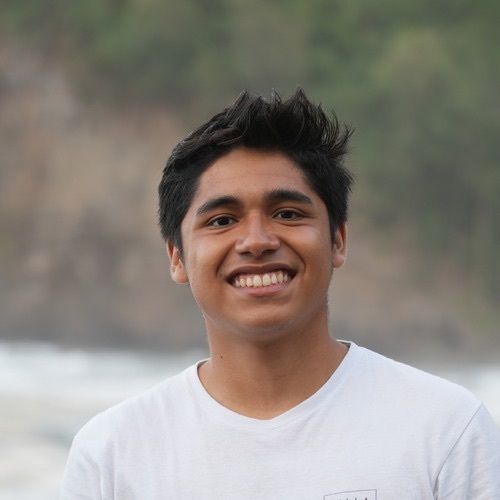
Researcher at Stanford
Hey! I am an undergraduate at UC Berkeley (go bears!) majoring in Electrical Engineering and Computer Sciences.
Currently, I am working in the Interactive Perception & Robot Learning Lab at Stanford, mentored by Professor Jeannette Bohg, Dr. Cherie Ho, and Carlota Parés-Morlans. I am also working in the Stanford Intelligent and Interactive Autonomous Systems Group (ILIAD), mentored by Professor Dorsa Sadigh, Dr. Jennifer Grannen, and Suvir Mirchandani.
My research focuses on deploying mobile manipulators in the wild. I'm interested in bringing robots into unstructured settings and have them continually self-improve.
MessyNav: Zero-Shot Interactive Navigation via Manipulation in Messy Environments
Conference on Robot Learning (CoRL), 2026
* Equal contribution
DexDrummer: In-Hand, Contact-Rich, and Long-Horizon Dexterous Robot Drumming
ICRA 2026 Workshop on Dexterity with Multifingered Hands
 CS 189/289A: Introduction to Machine Learning · UC Berkeley
Undergraduate Teaching Assistant
Aug 2026 – Present
 Data 6: Introduction to Computational Thinking with Data · UC Berkeley
Tutor
Jul 2024 – Dec 2024
 Computer Science Mentors · UC Berkeley
Section Instructor, CS 88: Computational Structures in Data Science
Feb 2023 – May 2023
 SEED Honors Scholars Program
Mentor
Aug 2025 – Present
 CodeBase
Project Advisor & Research Division Lead
Aug 2025 – Present
 Machine Learning @ Berkeley
Education Committee Officer
Jan 2023 – Present
 The Gates Scholarship
Squad Leader
Jun 2023
 Berkeley ANova
Education Committee Officer
Aug 2022 – Aug 2023